Our Robots
Explore our CAD mechanical models and physical robot iterations designed and engineered across various FIRST Tech Challenge seasons.
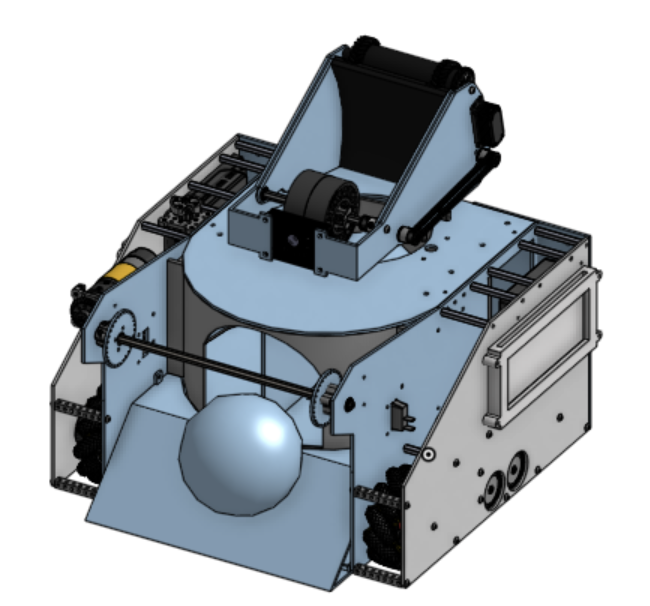
DECODE V1
Initial prototype chassis designed to test drive clearances, intake concepts, and basic autonomous routing.
- Drivetrain: Standard Mecanum drive setup
- Vision: OpenCV AprilTag tracking
- Focus: Core mechanics verification & chassis layout
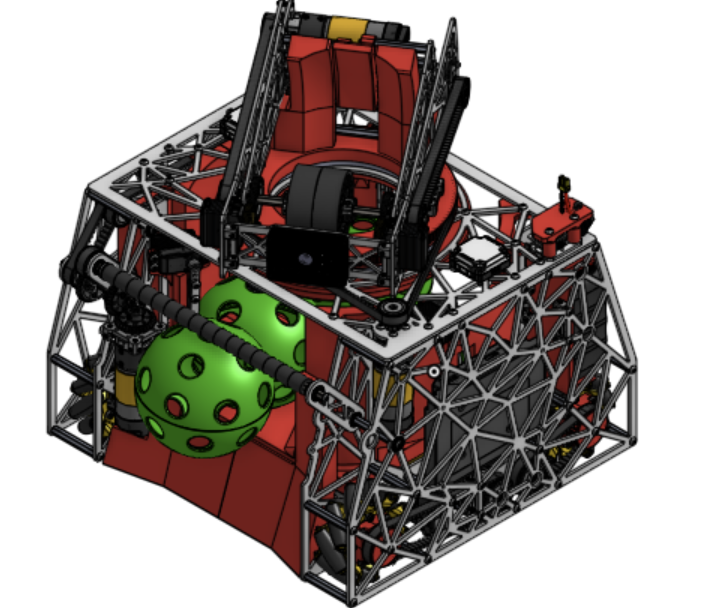
DECODE V2
Competitive iteration featuring structural plates, but was unable to be used due to time constraints.
- Drivetrain: High-speed compact Mecanum drive
- Vision: Limelight 3G localization & AprilTag pipeline
- Focus: Fast cycle automation & telemetry integration
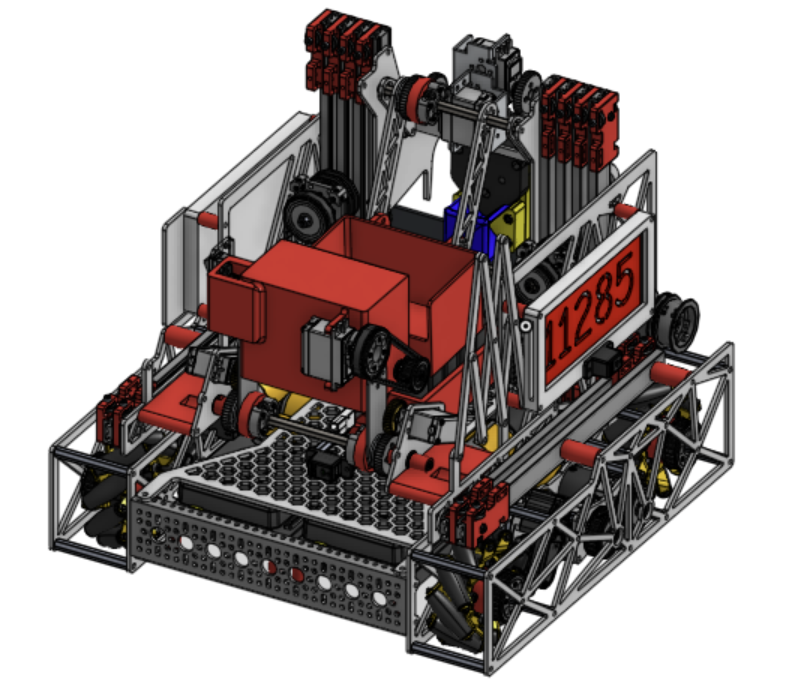
Into The Deep V1
Initial proof-of-concept chassis configured for baseline game piece pickup and autonomous deadwheel routing.
- Drivetrain: goBILDA Strafer Chassis (Mecanum)
- Intake: Active TPU compliant wheel roller
- Vision: OpenCV target tracking
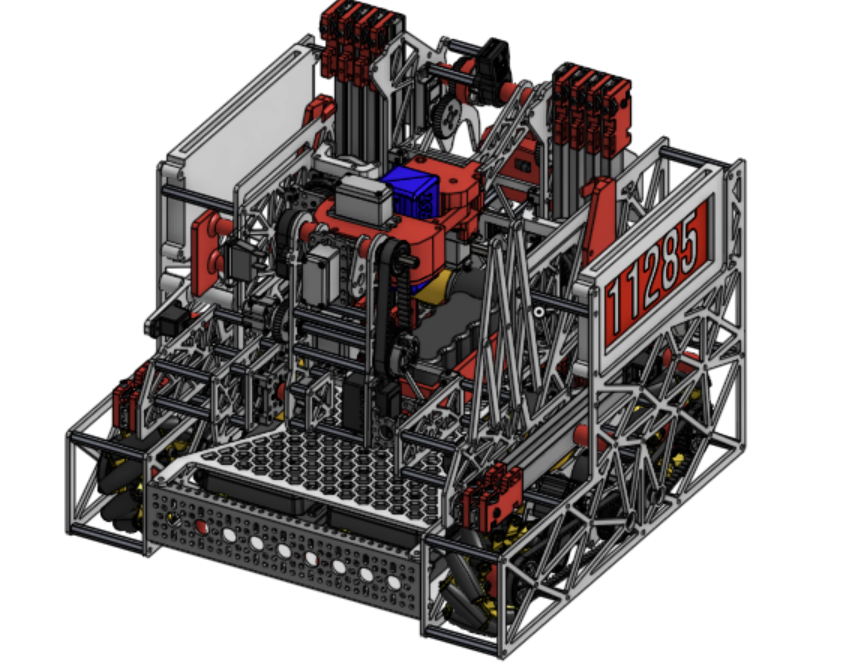
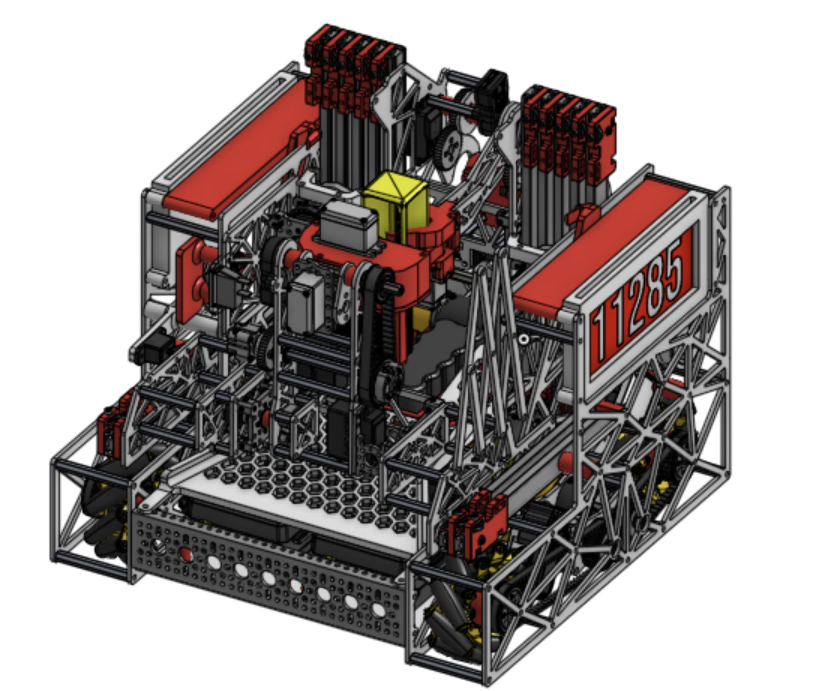
Into The Deep V2
Chassis revision integrating custom mounting brackets and initial multi-stage linear slide extension geometry.
- Structure: Custom laser-cut aluminum plates
- Lift: Multi-stage custom linear slides
- Focus: High basket reaching stability
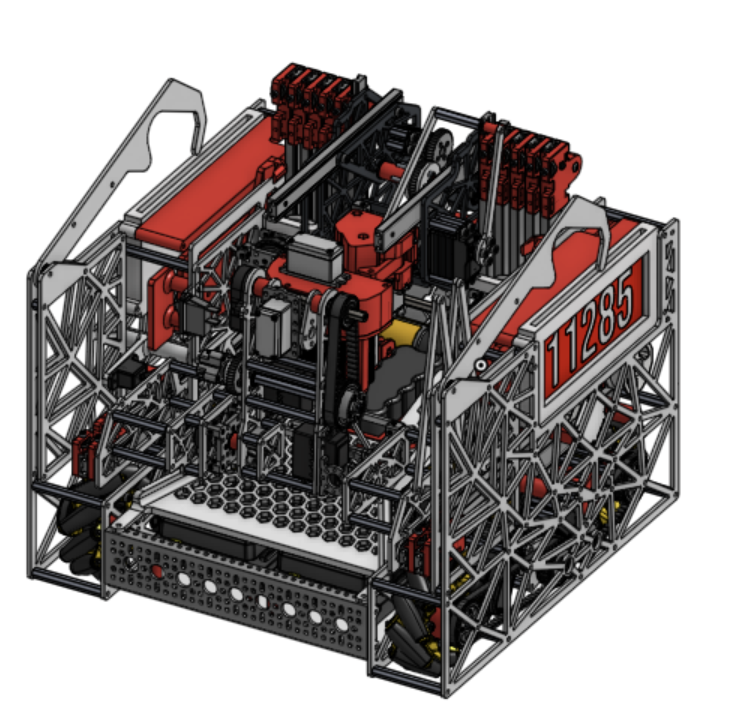
Into The Deep V2.5
Mid-season optimization focusing on mass reduction, wire routing management, and intake compliance.
- Weight: Strategic pocketing for structural efficiency
- Sensors: High-frequency optical distance sensors
- Focus: Reliability and autonomous path repeatability
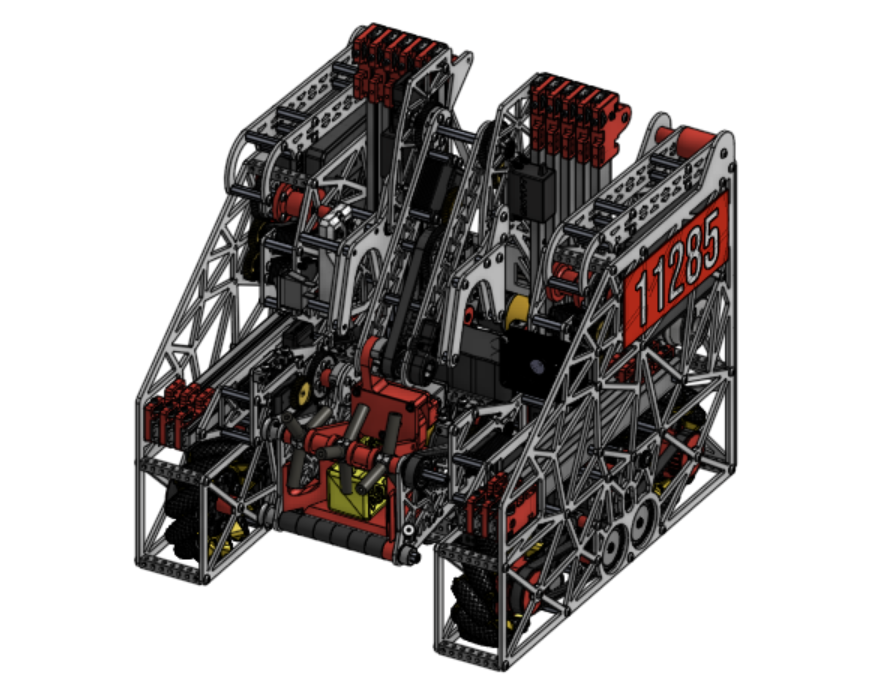
Into The Deep V3
League tournament build featuring CNC polycarbonate plates, reduced overall weight, and high-speed linear slides.
- Chassis: Low-profile Mecanum drive
- Control: RoadRunner spline trajectory profiling
- Focus: Maximum cycle speed & alliance synergy
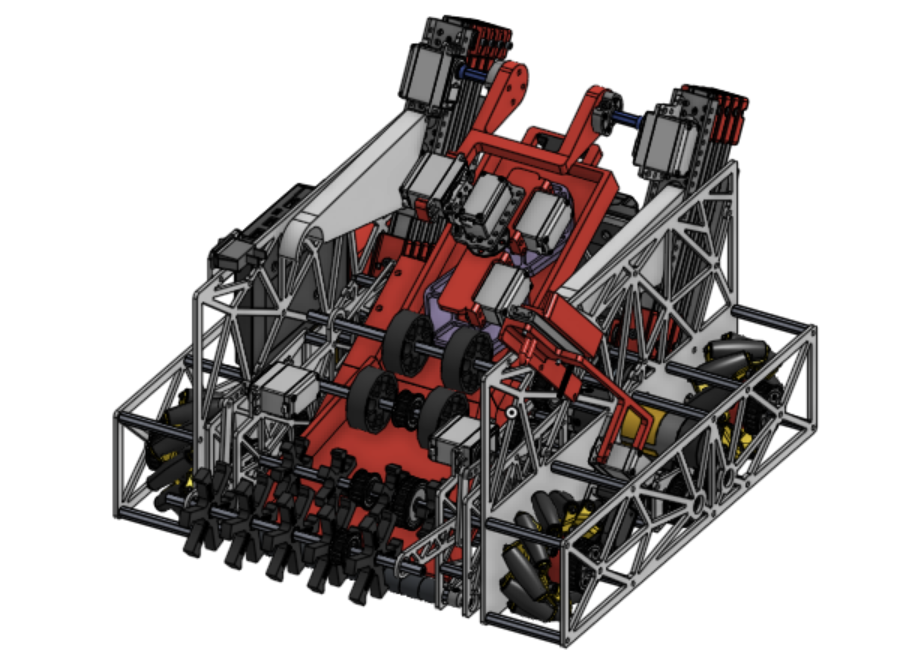
Into The Deep V4
Final championship revision with active dual-servo pitch & roll wrist claw end-effector and 3-wheel pinpoint deadwheel odometry.
- End-Effector: Precision pitch & roll wrist claw
- Odometry: 3-wheel pinpoint tracking module
- Weight: Optimized structure down to 28 lbs
CENTERSTAGE V1
Designed for rapid pixel intake from human player stations and automated backdrop alignment during teleop and autonomous periods.
- Drivetrain: 4-motor Mecanum drive
- Scoring: Servo-driven active pixel bucket
- Endgame: Drone launcher and tape suspension climb